Applications
Where tactile intelligence changes robot manipulation
Local contact feedback for real-world handling.
Touch has to earn its place
Adding another sensor to a robot only makes sense if it improves the performance or economics of the system. KiriSense is focused on applications where local contact feedback can improve pick success, reduce damage, shorten cycle times or reduce exception rates.
Industrial automation
Adaptive handling for variable parts
Local contact information could help robots respond to alignment, grip and surface variation during handling and assembly.
Logistics
Mixed-item fulfilment
Contact feedback could help confirm grasp and respond as item geometry, packaging and friction vary.
Food handling
Gentler manipulation
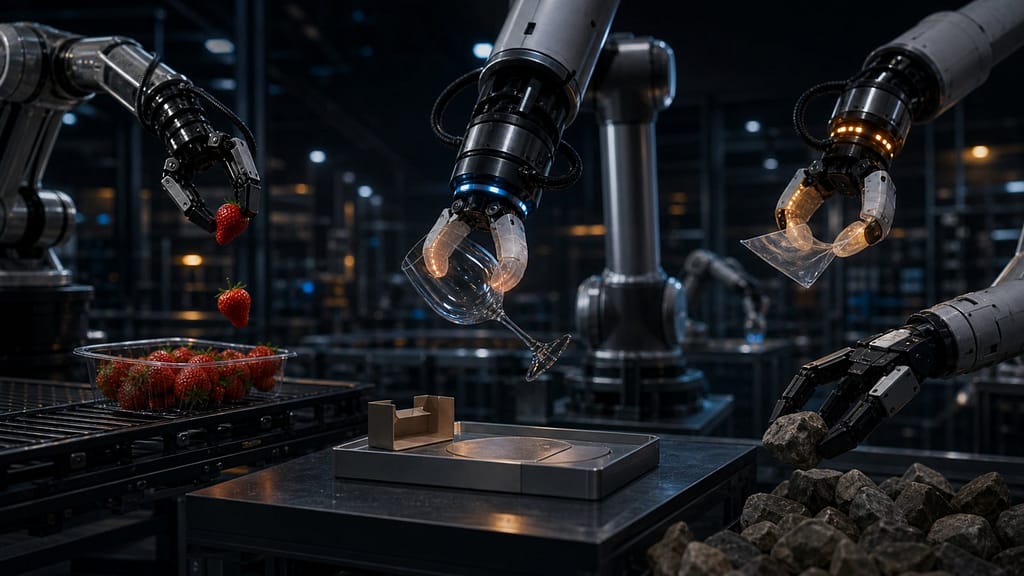
Variable shape, firmness and fragility make food handling difficult for vision-only automation. Local force and slip information could allow a gripper to adapt during contact rather than relying entirely on predetermined grip parameters.
Dexterous manipulation
Feedback during contact
Robotic hands and grippers need local information when an object shifts, deforms or begins to slip.
Humanoid robotics
Hands for human environments
Humanoid systems will need tactile information to handle the varied objects found in spaces designed for people.
From sensing principle to applications
Explore the tactile sensor architecture, our latest proof-of-concept results, and tactile feedback for robot hands and grippers.